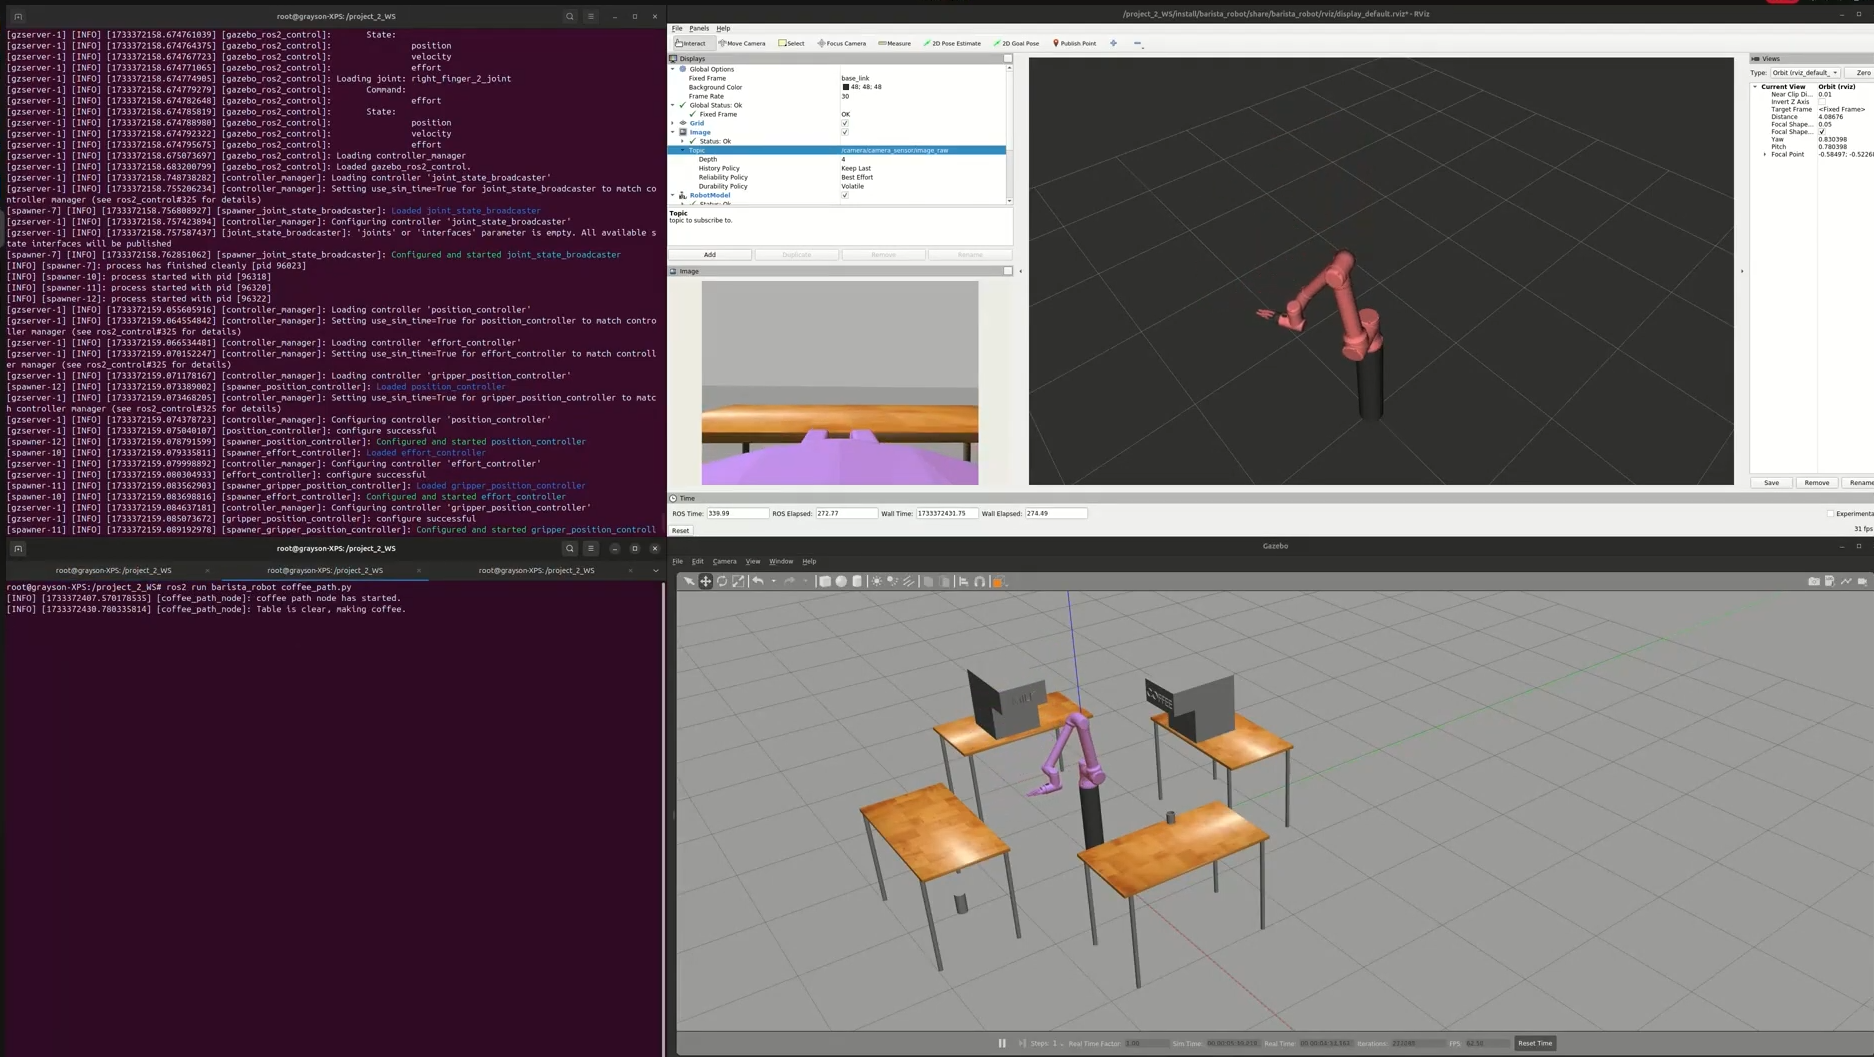
Autonomous 6-DOF Robotic Barista: Gazebo & ROS 2 Manipulation
Engineered an autonomous multi-station coffee preparation workcell utilizing a Universal Robots UR10e 6-DOF manipulator, Robotiq 2F-140 gripper, and Intel RealSense D435 in ROS 2 Humble and Gazebo. Features analytical DH forward kinematics, Jacobian pseudoinverse trajectory tracking, singularity-free workspace optimization, and joint effort physics stabilization.