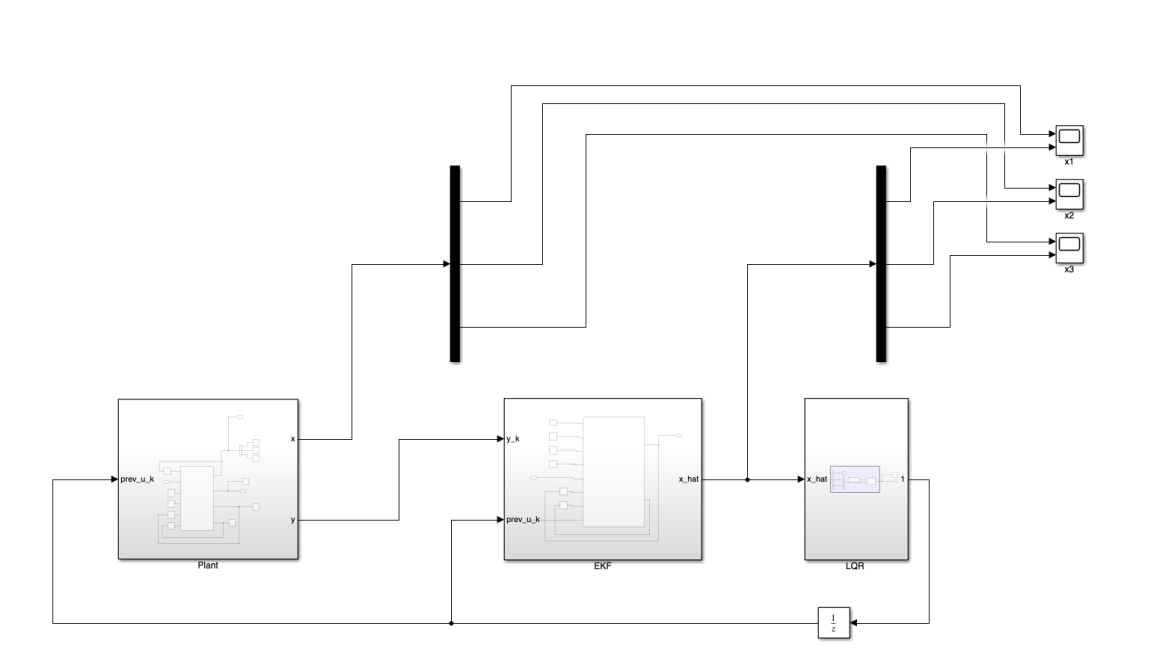
State Estimation & Optimal LQR Control for Underwater Optical Alignment
Recreated and verified an augmented 3-state state-space control framework for Underwater Wireless Optical Communication (UWOC). Implemented an Extended Kalman Filter (EKF) with dual-measurement observability paired with a Linear Quadratic Regulator (LQR) in MATLAB/Simulink to achieve sub-two-second optical alignment under attenuation and sensor noise.