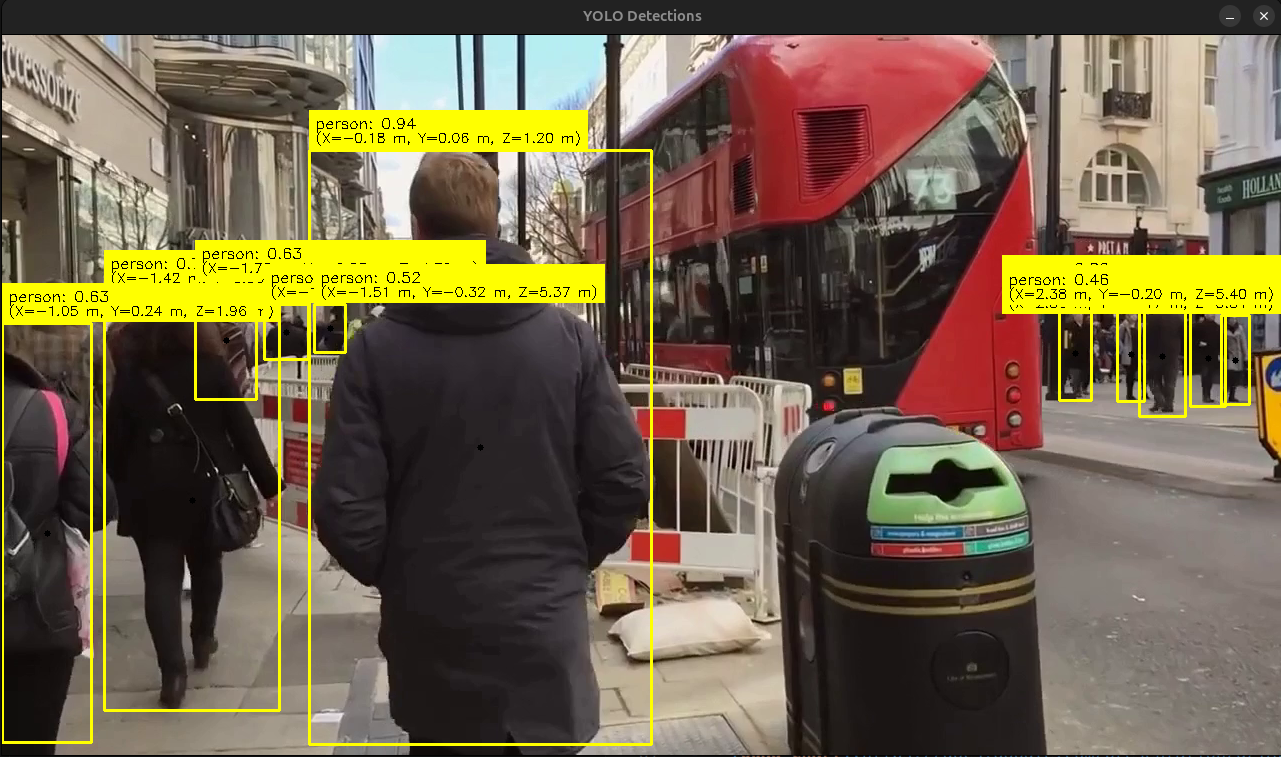
Monocular 3D perception pipeline detecting humans and estimating metric (X, Y, Z) coordinates

ACME Monocular Perception & 3D Spatial Tracking Module

Engineered a production-grade C++ monocular perception library for ACME Robotics fusing YOLOv5 2D object detection with the ‘Depth Anything’ foundation model. Delivers real-time 3D human obstacle detection and metric spatial localization from a single RGB camera stream, supported by a comprehensive CMake, CTest, Cppcheck, and Doxygen CI/CD suite.
October 18, 2025
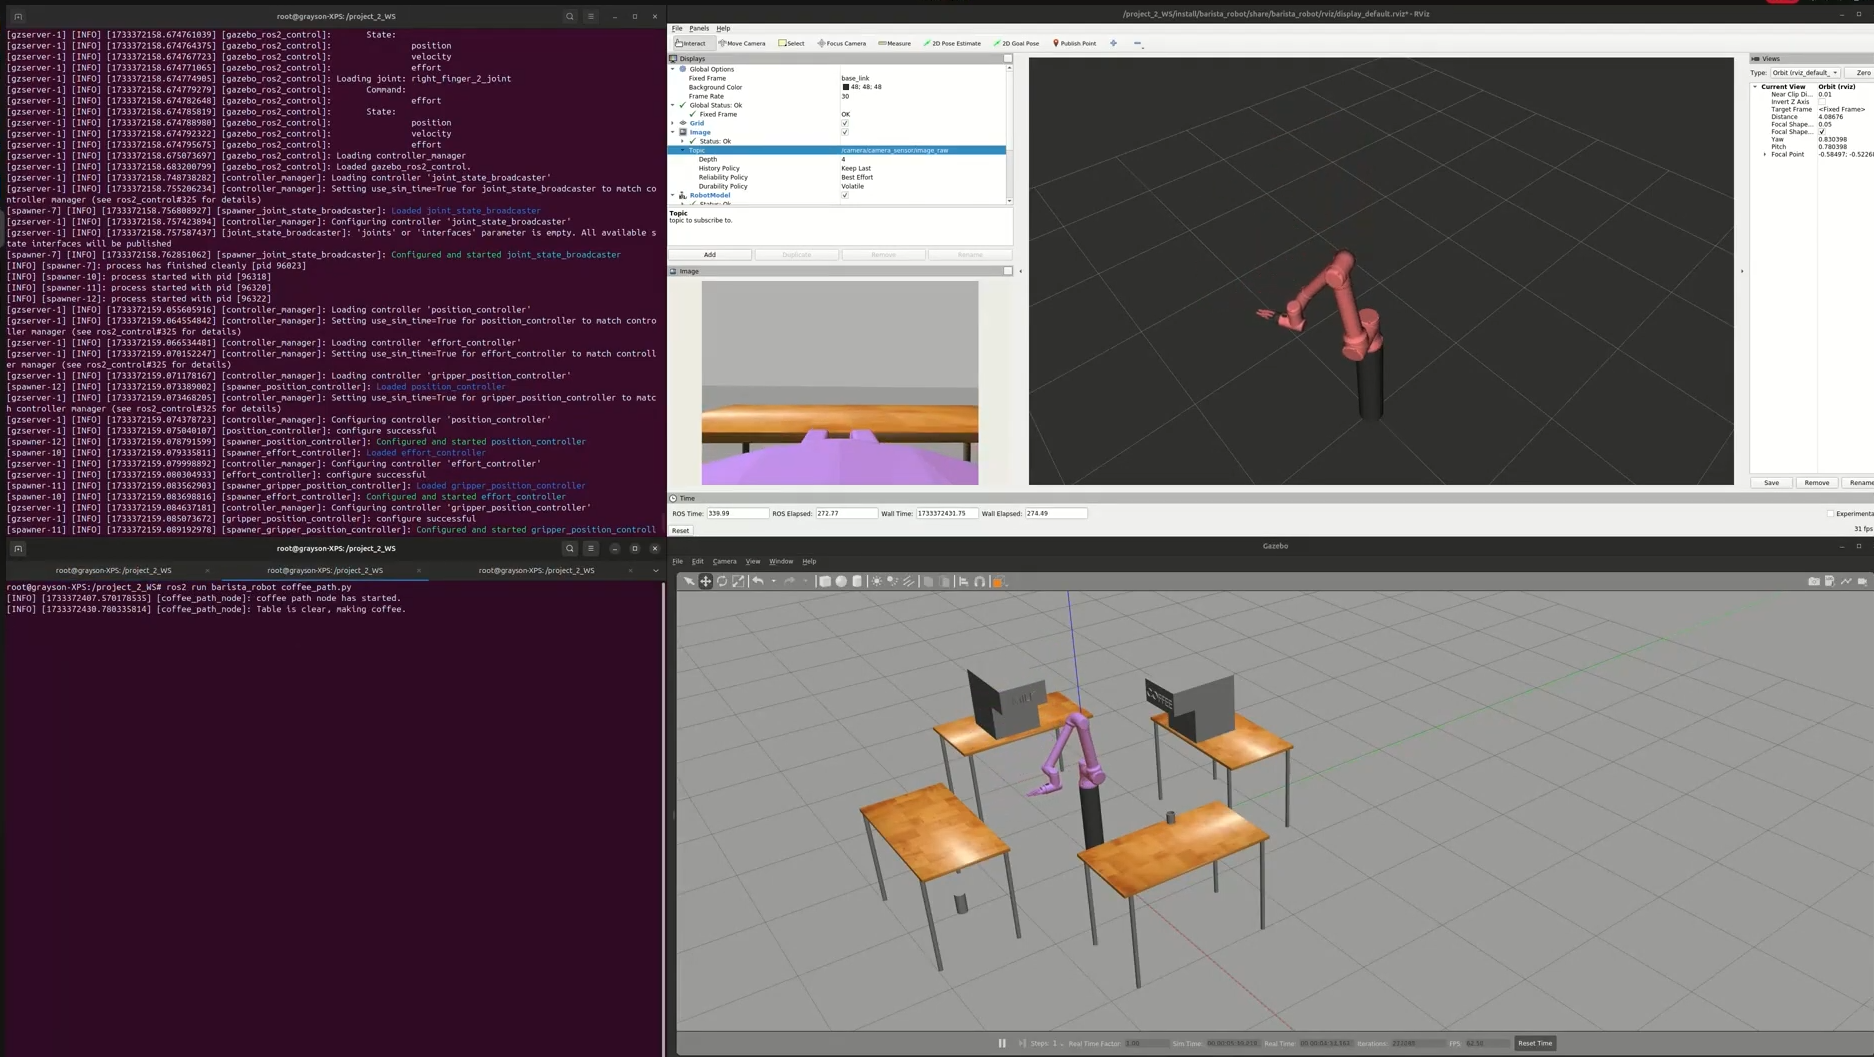
Autonomous 6-DOF Barista Robot Gazebo simulation, RViz perception, and ROS 2 control console

Autonomous 6-DOF Robotic Barista: Gazebo & ROS 2 Manipulation

Engineered an autonomous multi-station coffee preparation workcell utilizing a Universal Robots UR10e 6-DOF manipulator, Robotiq 2F-140 gripper, and Intel RealSense D435 in ROS 2 Humble and Gazebo. Features analytical DH forward kinematics, Jacobian pseudoinverse trajectory tracking, singularity-free workspace optimization, and joint effort physics stabilization.

March 1, 2025