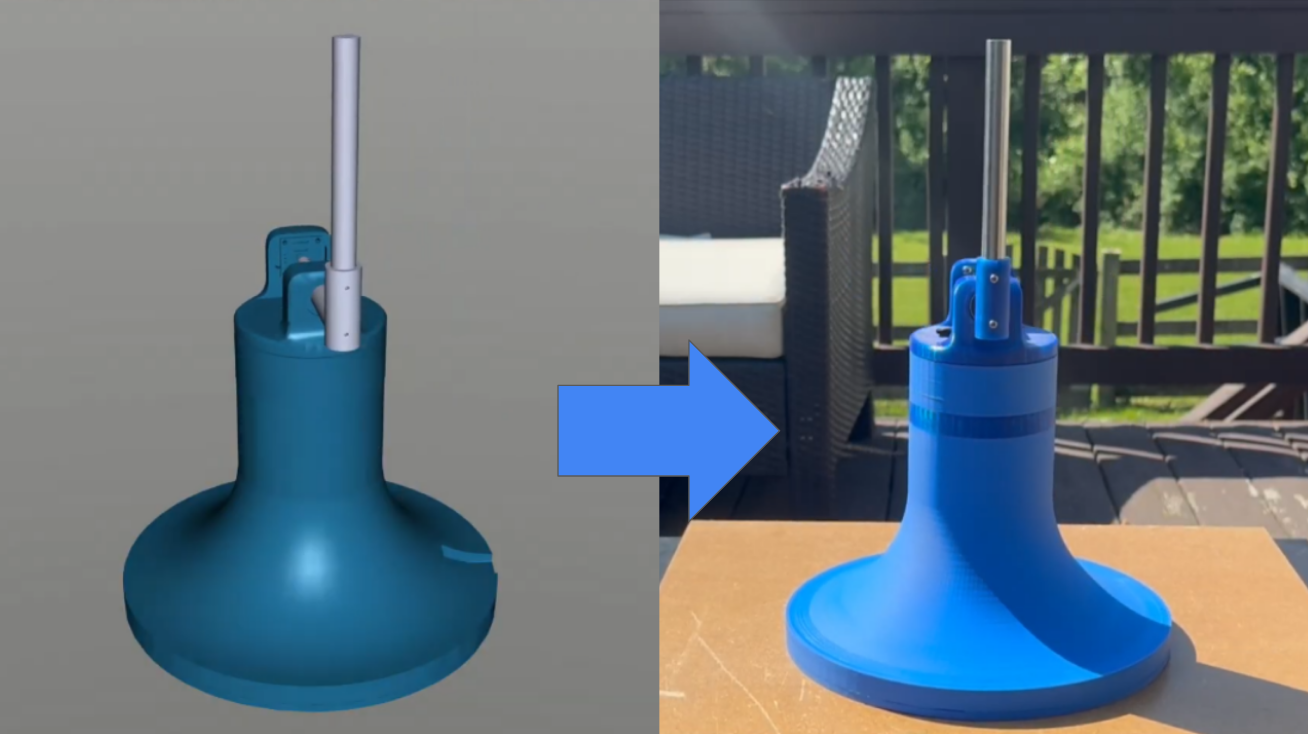
Sim2Real Furuta Pendulum — physical hardware and MuJoCo simulation

Sim2Real Transfer: Robust RL Control of a Furuta Pendulum

Trained a PPO control policy in a custom MuJoCo Gymnasium environment and achieved zero-shot transfer onto an ESP32 microcontroller. Balances continuously for over an hour on physical hardware with no additional tuning.
May 1, 2026
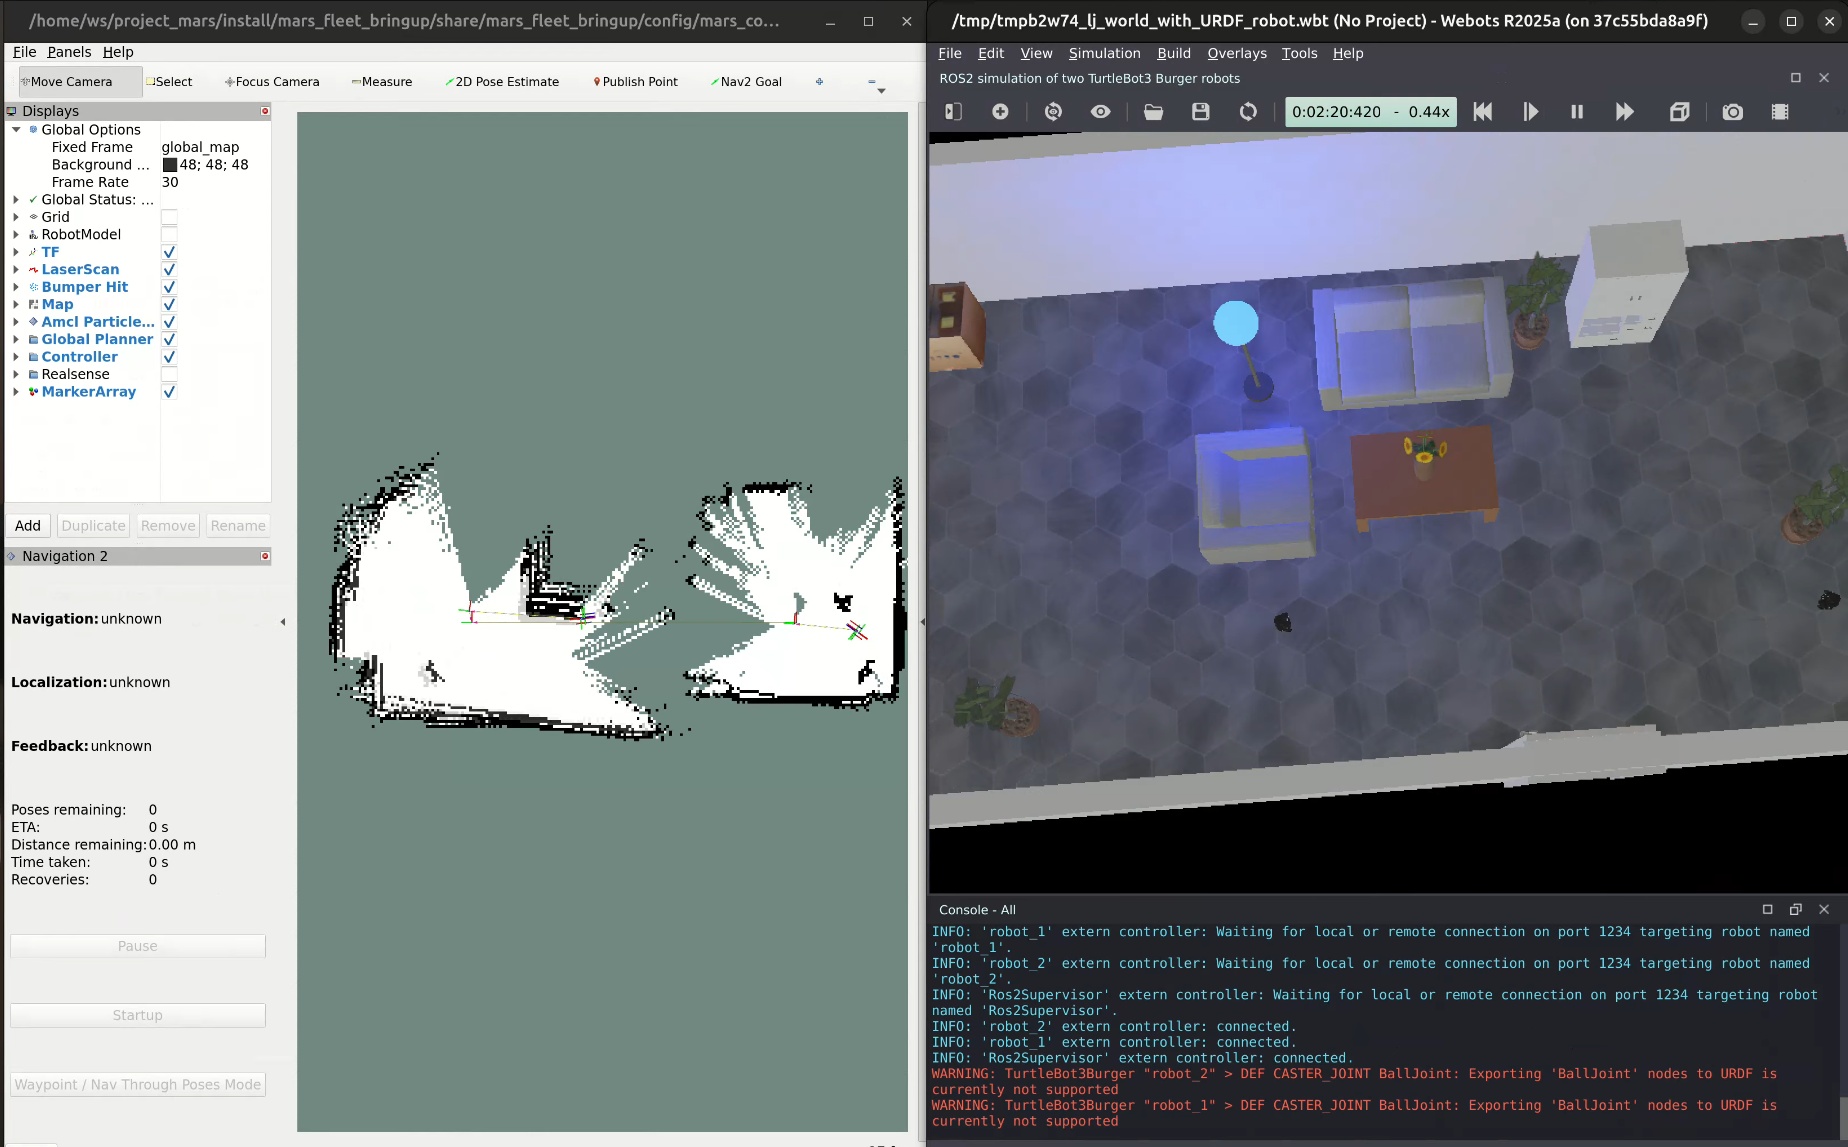
Project MARS Multi-Agent Robotic SLAM in Webots and RViz2

Project MARS: Multi-Agent Robotic SLAM

Scalable multi-robot mapping and autonomous exploration system in ROS 2 Humble and Webots. Orchestrates a TurtleBot3 fleet using slam_toolbox, REP-105 compliant TF trees, deterministic occupancy-grid fusion in mars_overseer, and an automated TDD CI/CD pipeline.

November 22, 2025
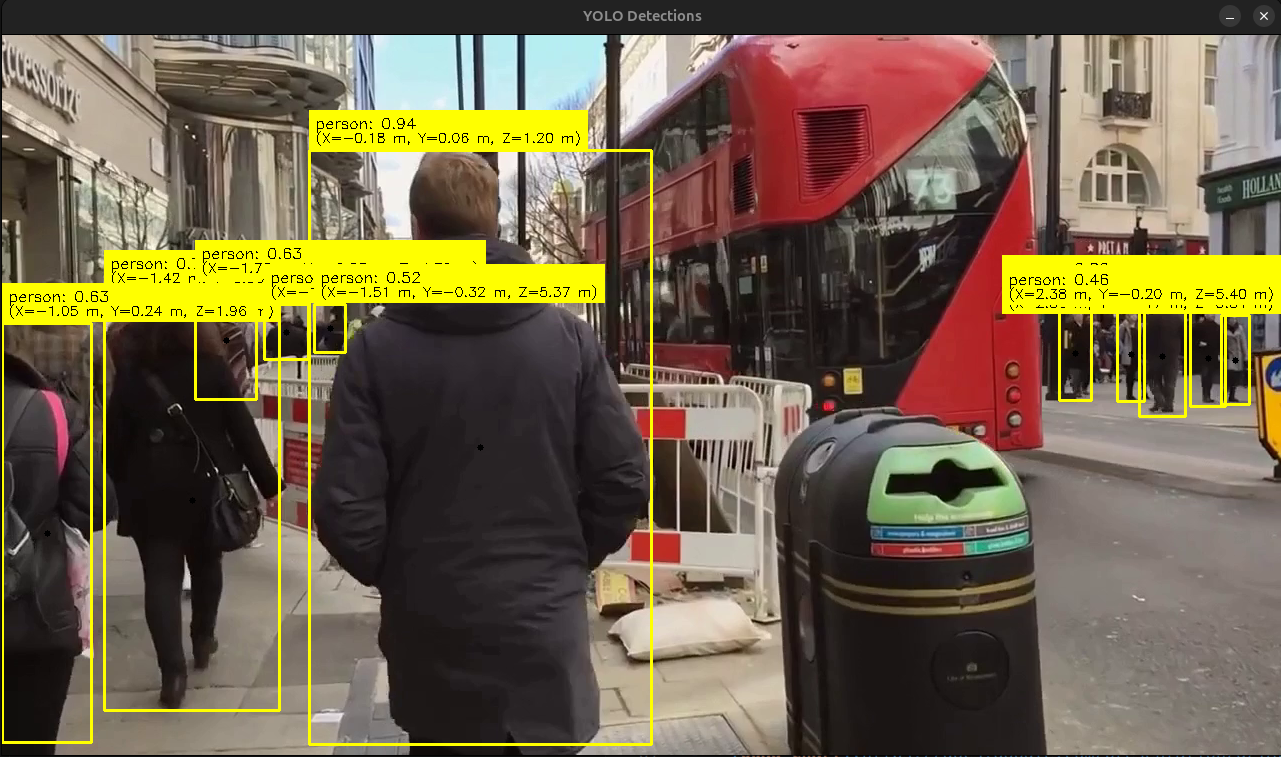
Monocular 3D perception pipeline detecting humans and estimating metric (X, Y, Z) coordinates

ACME Monocular Perception & 3D Spatial Tracking Module

Engineered a production-grade C++ monocular perception library for ACME Robotics fusing YOLOv5 2D object detection with the ‘Depth Anything’ foundation model. Delivers real-time 3D human obstacle detection and metric spatial localization from a single RGB camera stream, supported by a comprehensive CMake, CTest, Cppcheck, and Doxygen CI/CD suite.

October 18, 2025