Projects
A collection of engineering and robotics projects spanning embedded hardware, autonomy, machine learning, and more. Click any card to read the full write-up.
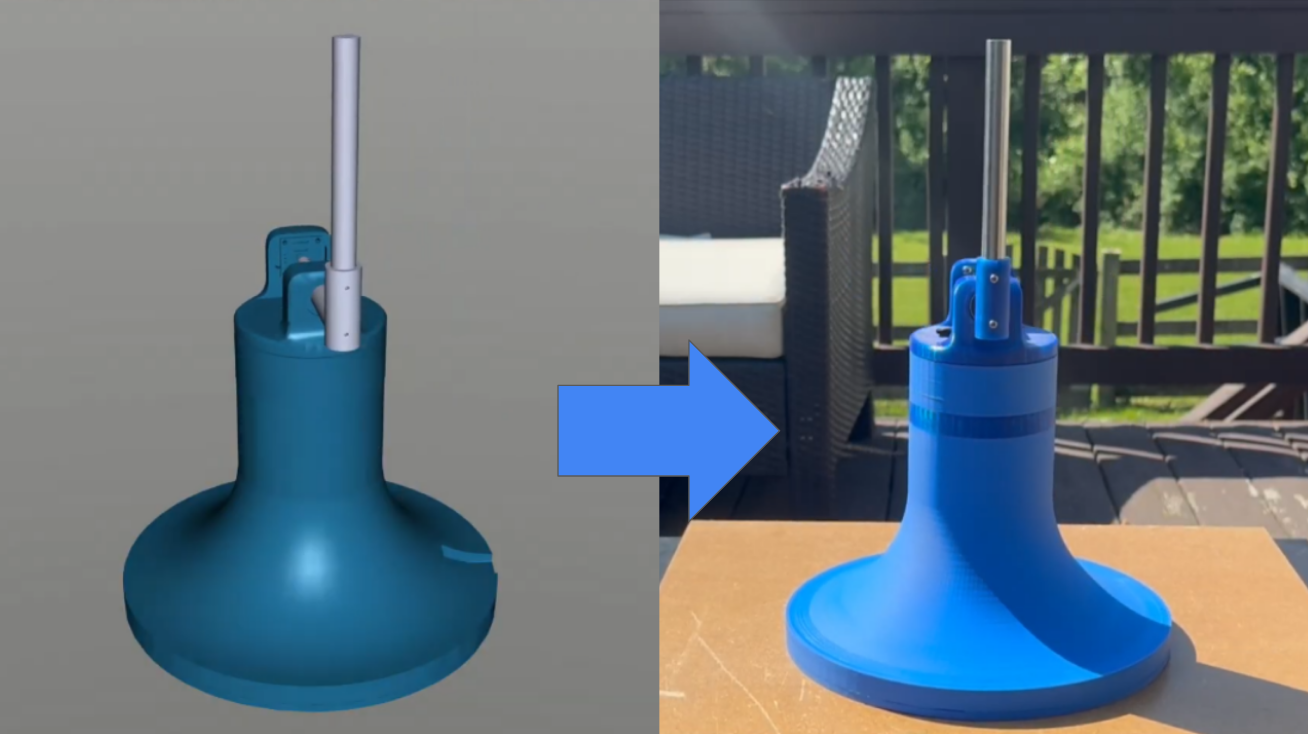
Sim2Real Transfer: Robust RL Control of a Furuta Pendulum
Trained a PPO control policy in a custom MuJoCo Gymnasium environment and achieved zero-shot transfer onto an ESP32 microcontroller. Balances continuously for over an hour on physical hardware with no additional tuning.
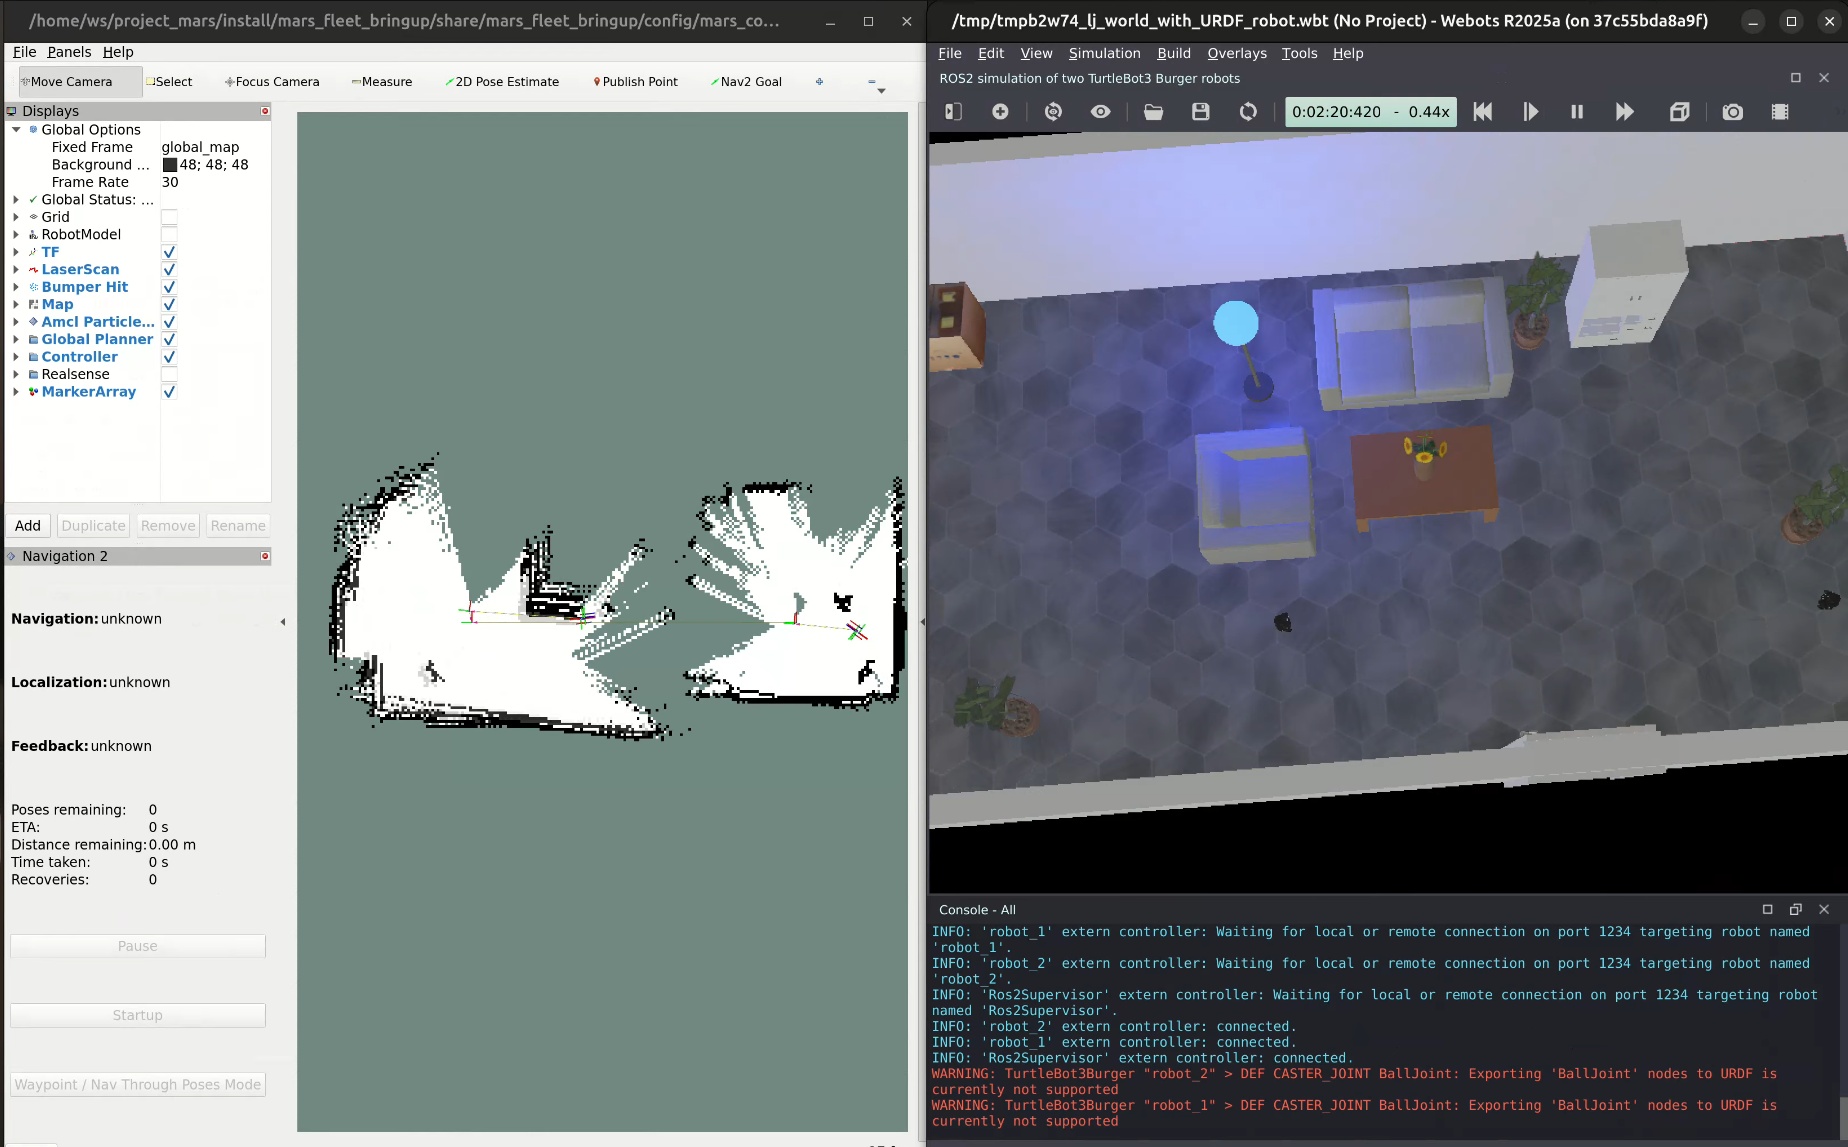
Project MARS: Multi-Agent Robotic SLAM
Scalable multi-robot mapping and autonomous exploration system in ROS 2 Humble and Webots. Orchestrates a TurtleBot3 fleet using slam_toolbox, REP-105 compliant TF trees, deterministic occupancy-grid fusion in mars_overseer, and an automated TDD CI/CD pipeline.
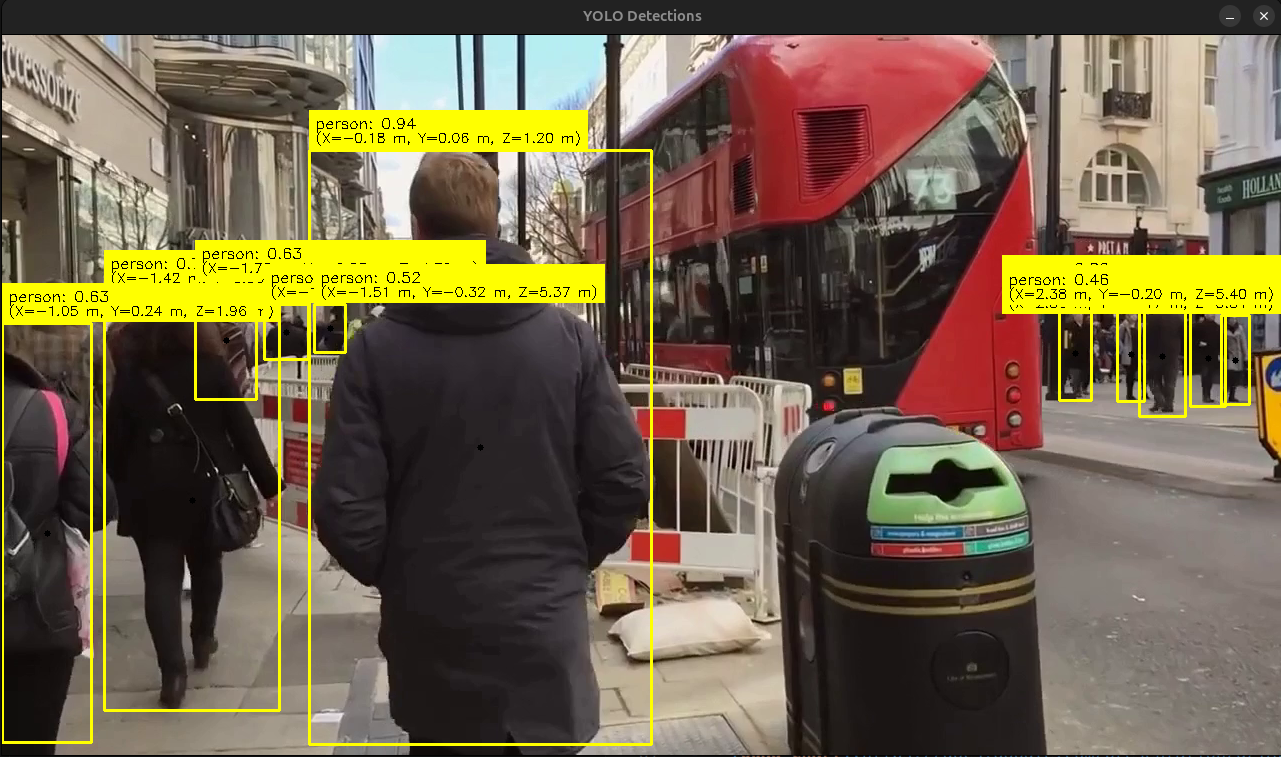
ACME Monocular Perception & 3D Spatial Tracking Module
Engineered a production-grade C++ monocular perception library for ACME Robotics fusing YOLOv5 2D object detection with the 'Depth Anything' foundation model. Delivers real-time 3D human obstacle detection and metric spatial localization from a single RGB camera stream, supported by a comprehensive CMake, CTest, Cppcheck, and Doxygen CI/CD suite.
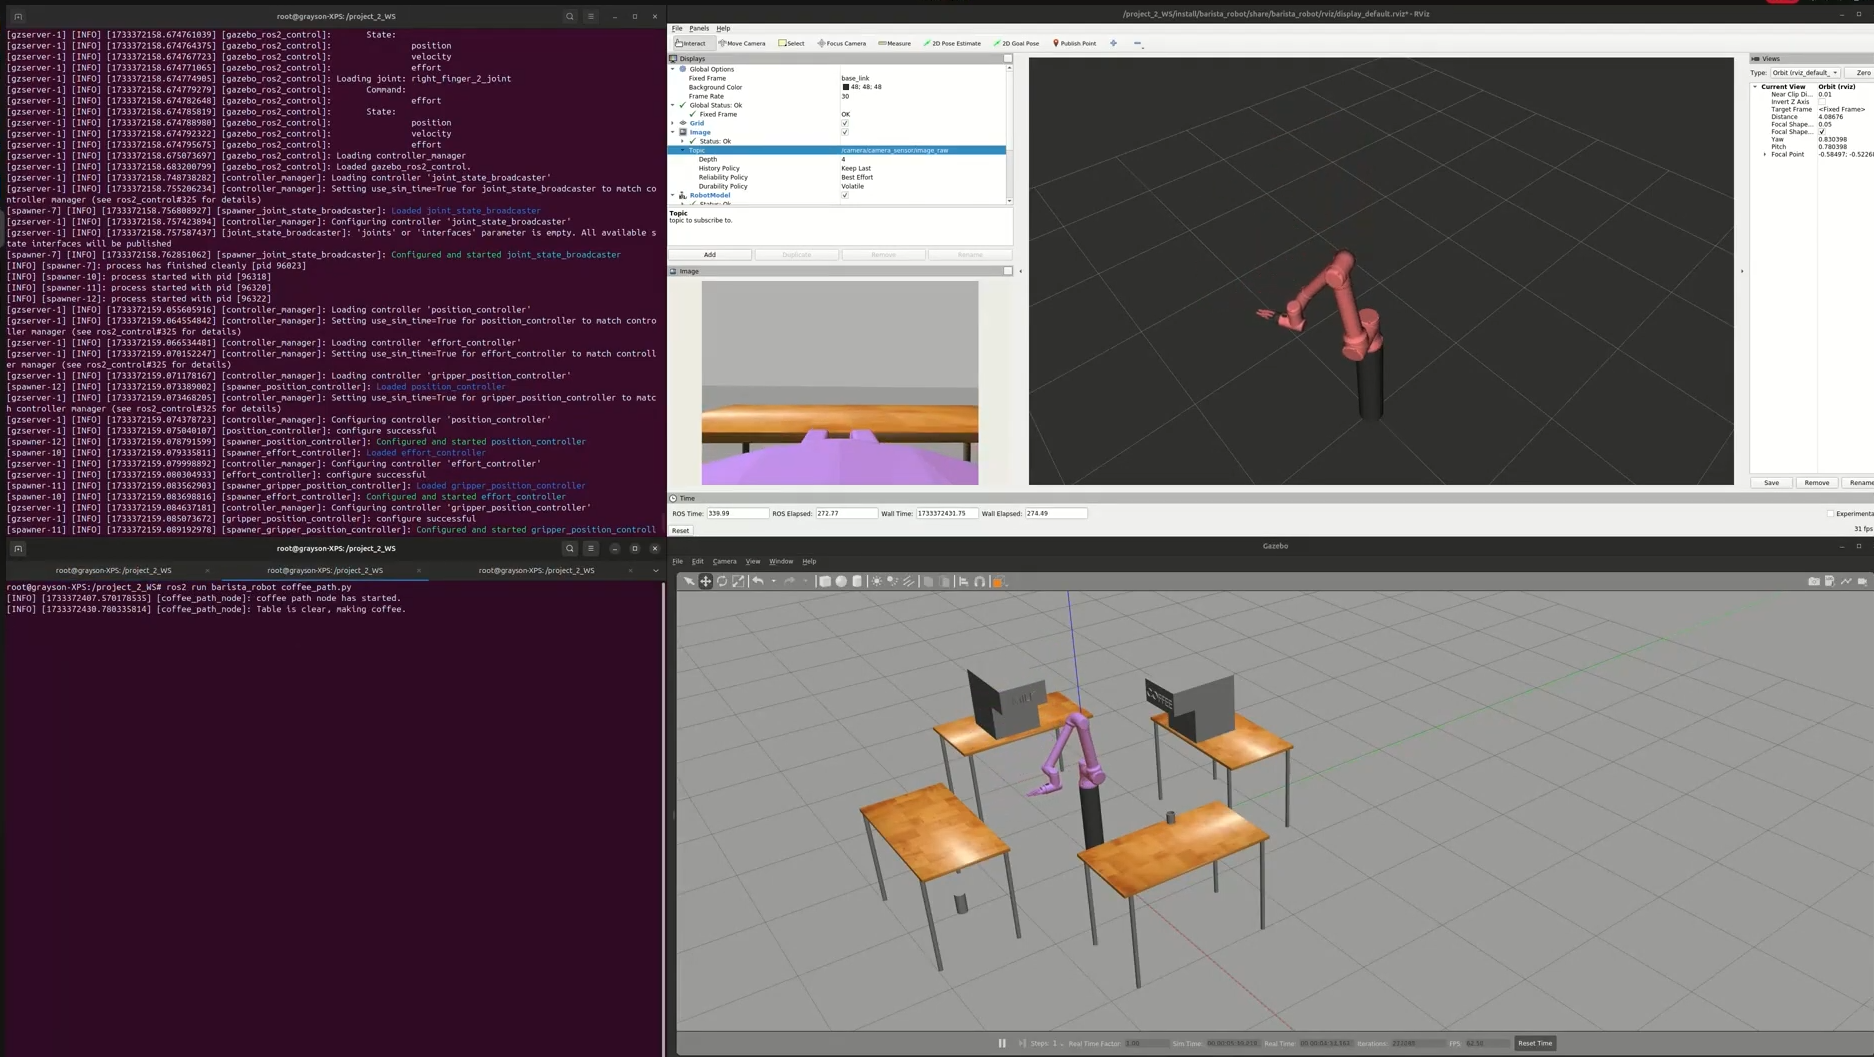
Autonomous 6-DOF Robotic Barista: Gazebo & ROS 2 Manipulation
Engineered an autonomous multi-station coffee preparation workcell utilizing a Universal Robots UR10e 6-DOF manipulator, Robotiq 2F-140 gripper, and Intel RealSense D435 in ROS 2 Humble and Gazebo. Features analytical DH forward kinematics, Jacobian pseudoinverse trajectory tracking, singularity-free workspace optimization, and joint effort physics stabilization.
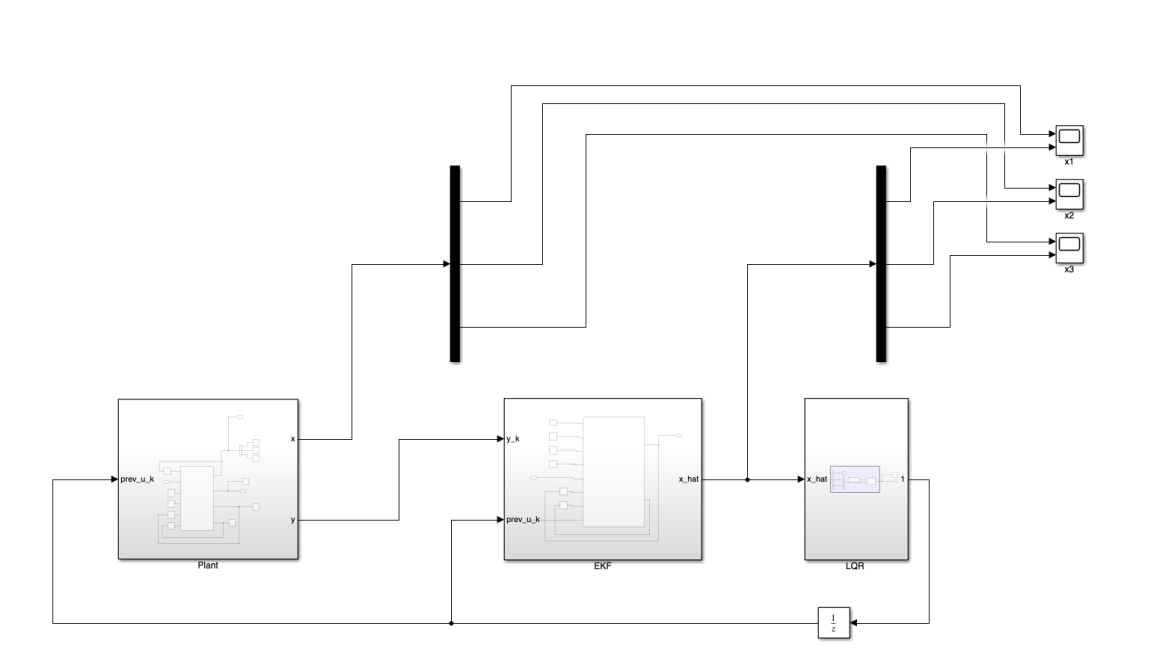
State Estimation & Optimal LQR Control for Underwater Optical Alignment
Recreated and verified an augmented 3-state state-space control framework for Underwater Wireless Optical Communication (UWOC). Implemented an Extended Kalman Filter (EKF) with dual-measurement observability paired with a Linear Quadratic Regulator (LQR) in MATLAB/Simulink to achieve sub-two-second optical alignment under attenuation and sensor noise.
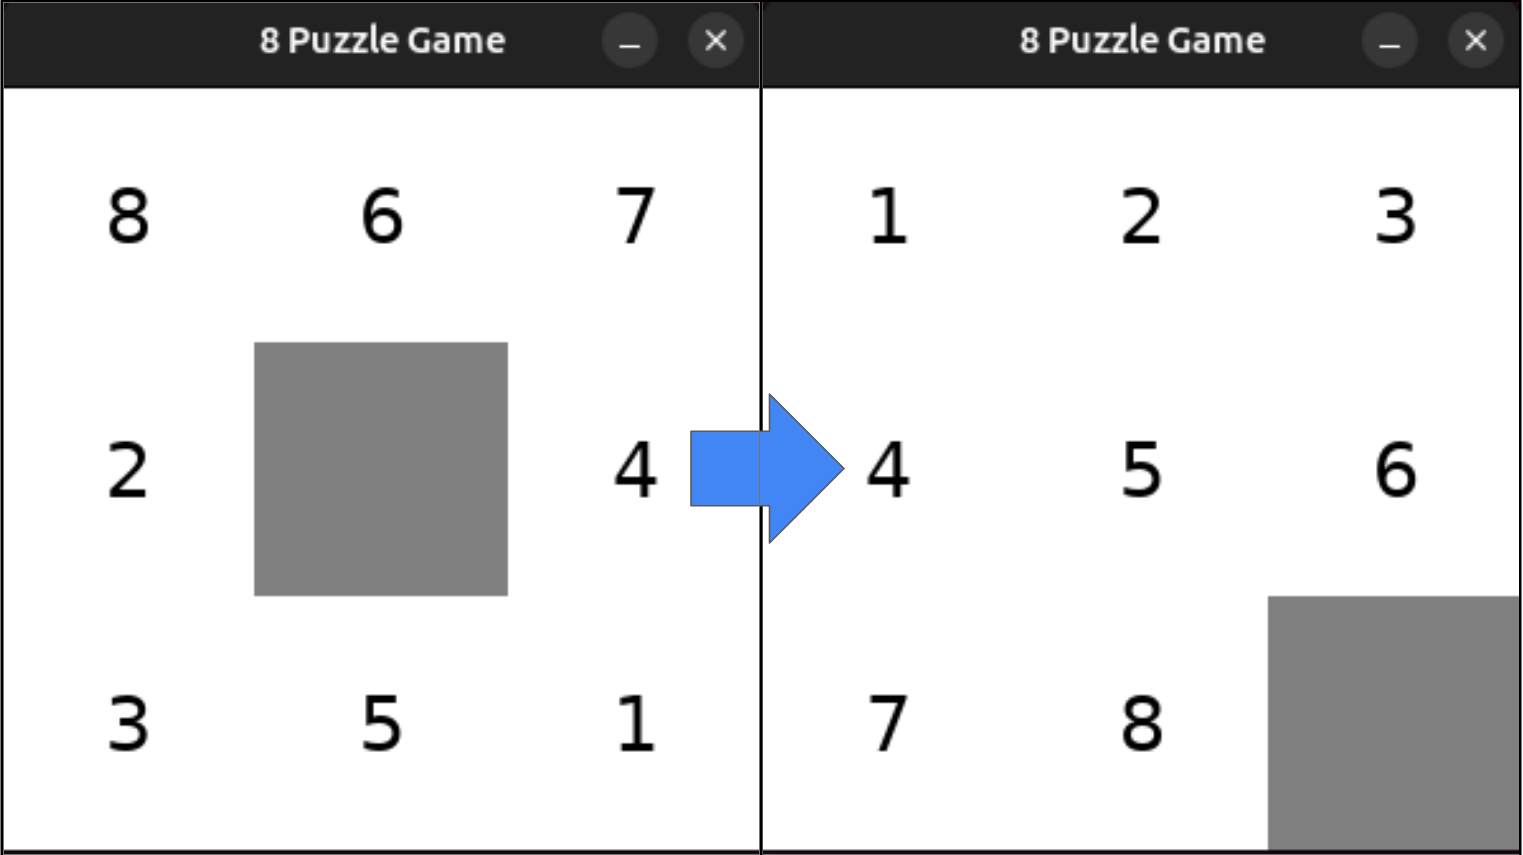
8-Puzzle Solver and Graphical Visualization
Optimal 8-Puzzle solver implementing Breadth-First Search (BFS) with hash-set visited state pruning in Python. Features automated file serialization (Nodes.txt, nodePath.txt) and a custom Pygame graphical engine animating the step-by-step solution path.
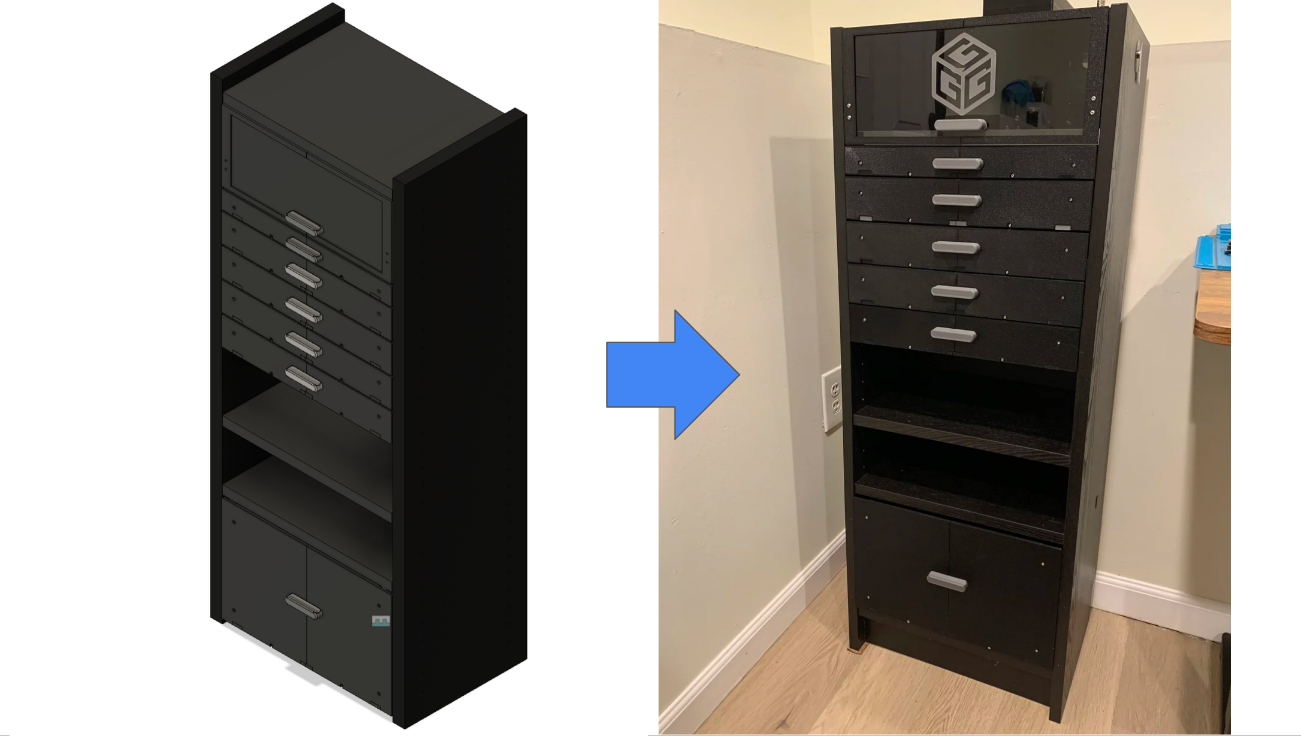
Custom Modular Storage System: Ikea Billy Bookcase
Designed and manufactured a custom 3D-printed modular sliding drawer system for the Ikea Billy Bookcase, featuring a low-friction rolling-ball slide mechanism, standardized unit scaling, and a magnetic flush-mount acrylic enclosure.
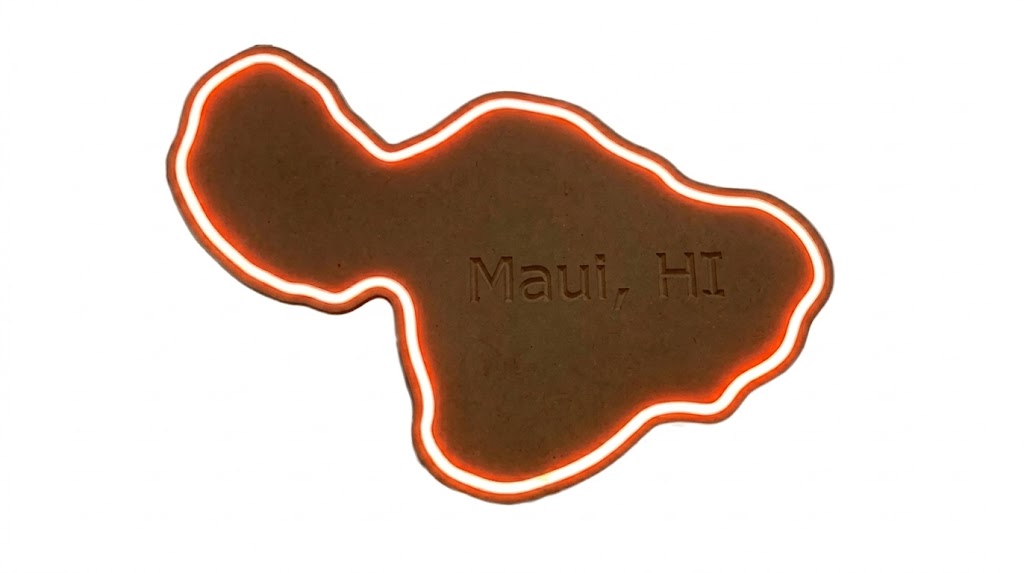
CNC-Routed LED Sign: Maui, Hawaii
Designed and manufactured a custom illuminated sign of the island of Maui on a Shapeoko 3 XXL CNC router, featuring multi-tool CAM toolpaths, custom V-carve engraving, and a recessed LED lighting system.
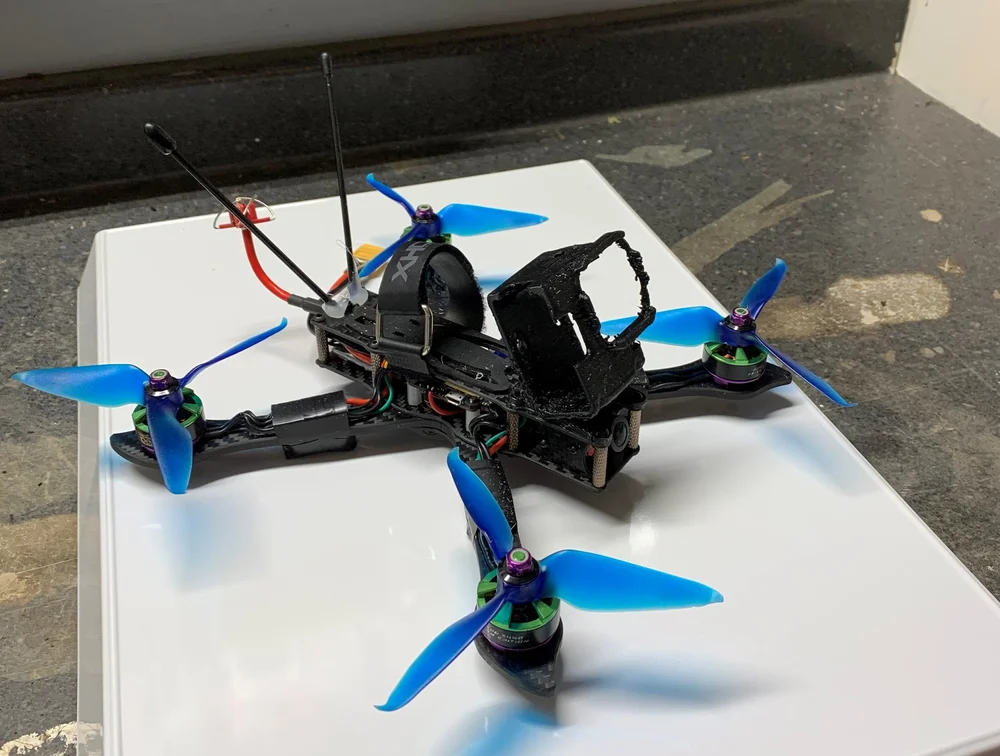
Custom FPV Racing Drones
Designed, built, and tuned custom high-performance FPV quadcopters since 2016, developing hands-on mastery in precision micro-soldering, flight controller configuration, PID loop tuning, and custom CAD airframe components.
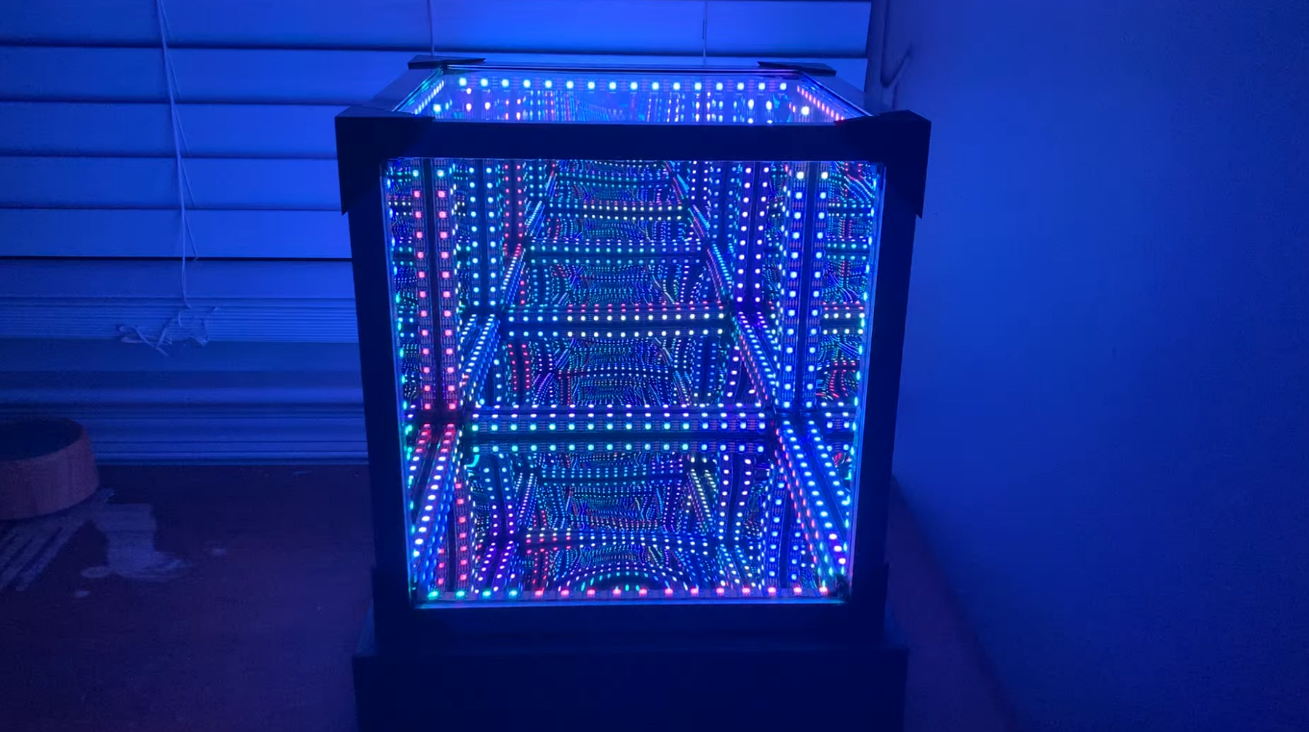
Infinity Mirror LED Hyper Cube
Engineered and fabricated a custom infinity mirror LED cube from scratch, integrating 300+ individually addressable LEDs, concealed wire routing through structural acrylic tubing, and a Bluetooth smartphone controller — including hardware troubleshooting to resolve matrix voltage drop.
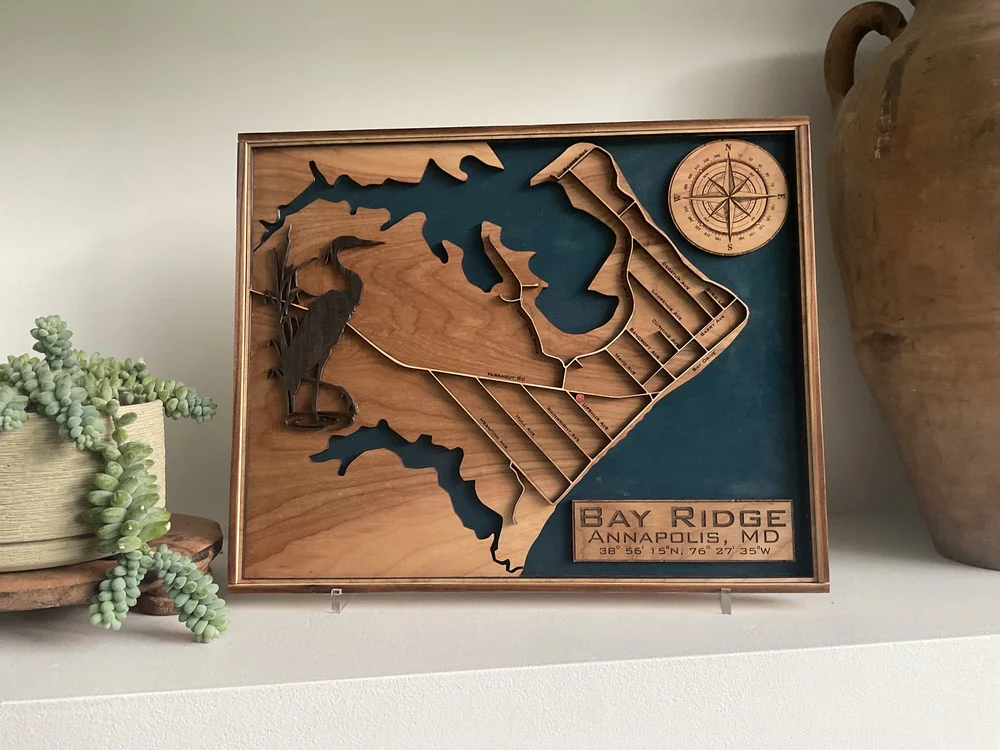
Topographical Laser Cut Maps: Prototype to Production
Engineered a multi-layer topographical map from raw GIS data through to a streamlined production workflow, fulfilling 43 custom orders with a 75% reduction in total build time and a 50% cut in CNC laser cycle time.
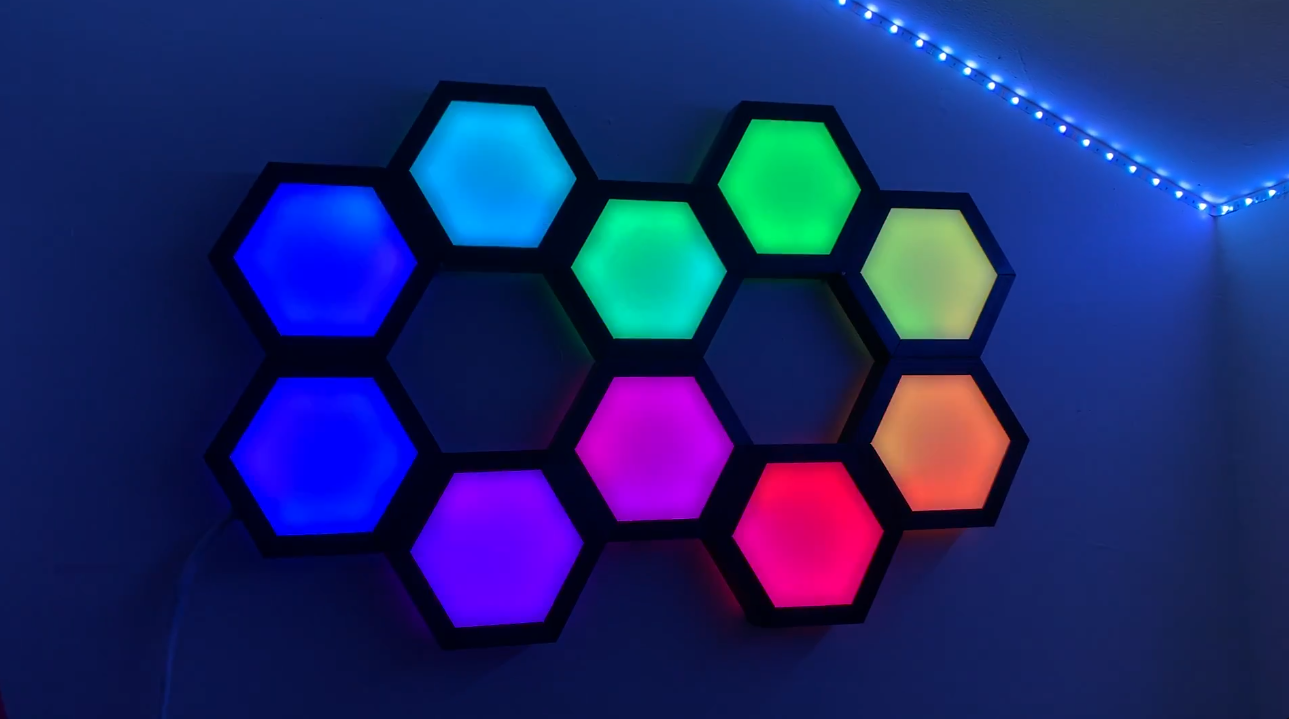
Custom Arduino-Controlled NanoLeaf LED Installation
Built an interactive wall installation featuring 280 individually addressable NeoPixels in handcrafted wooden hexagonal frames. Programmed custom Arduino C++ firmware with hardware interrupt mode-switching, analog potentiometer brightness mapping, and multi-point 5V power injection.
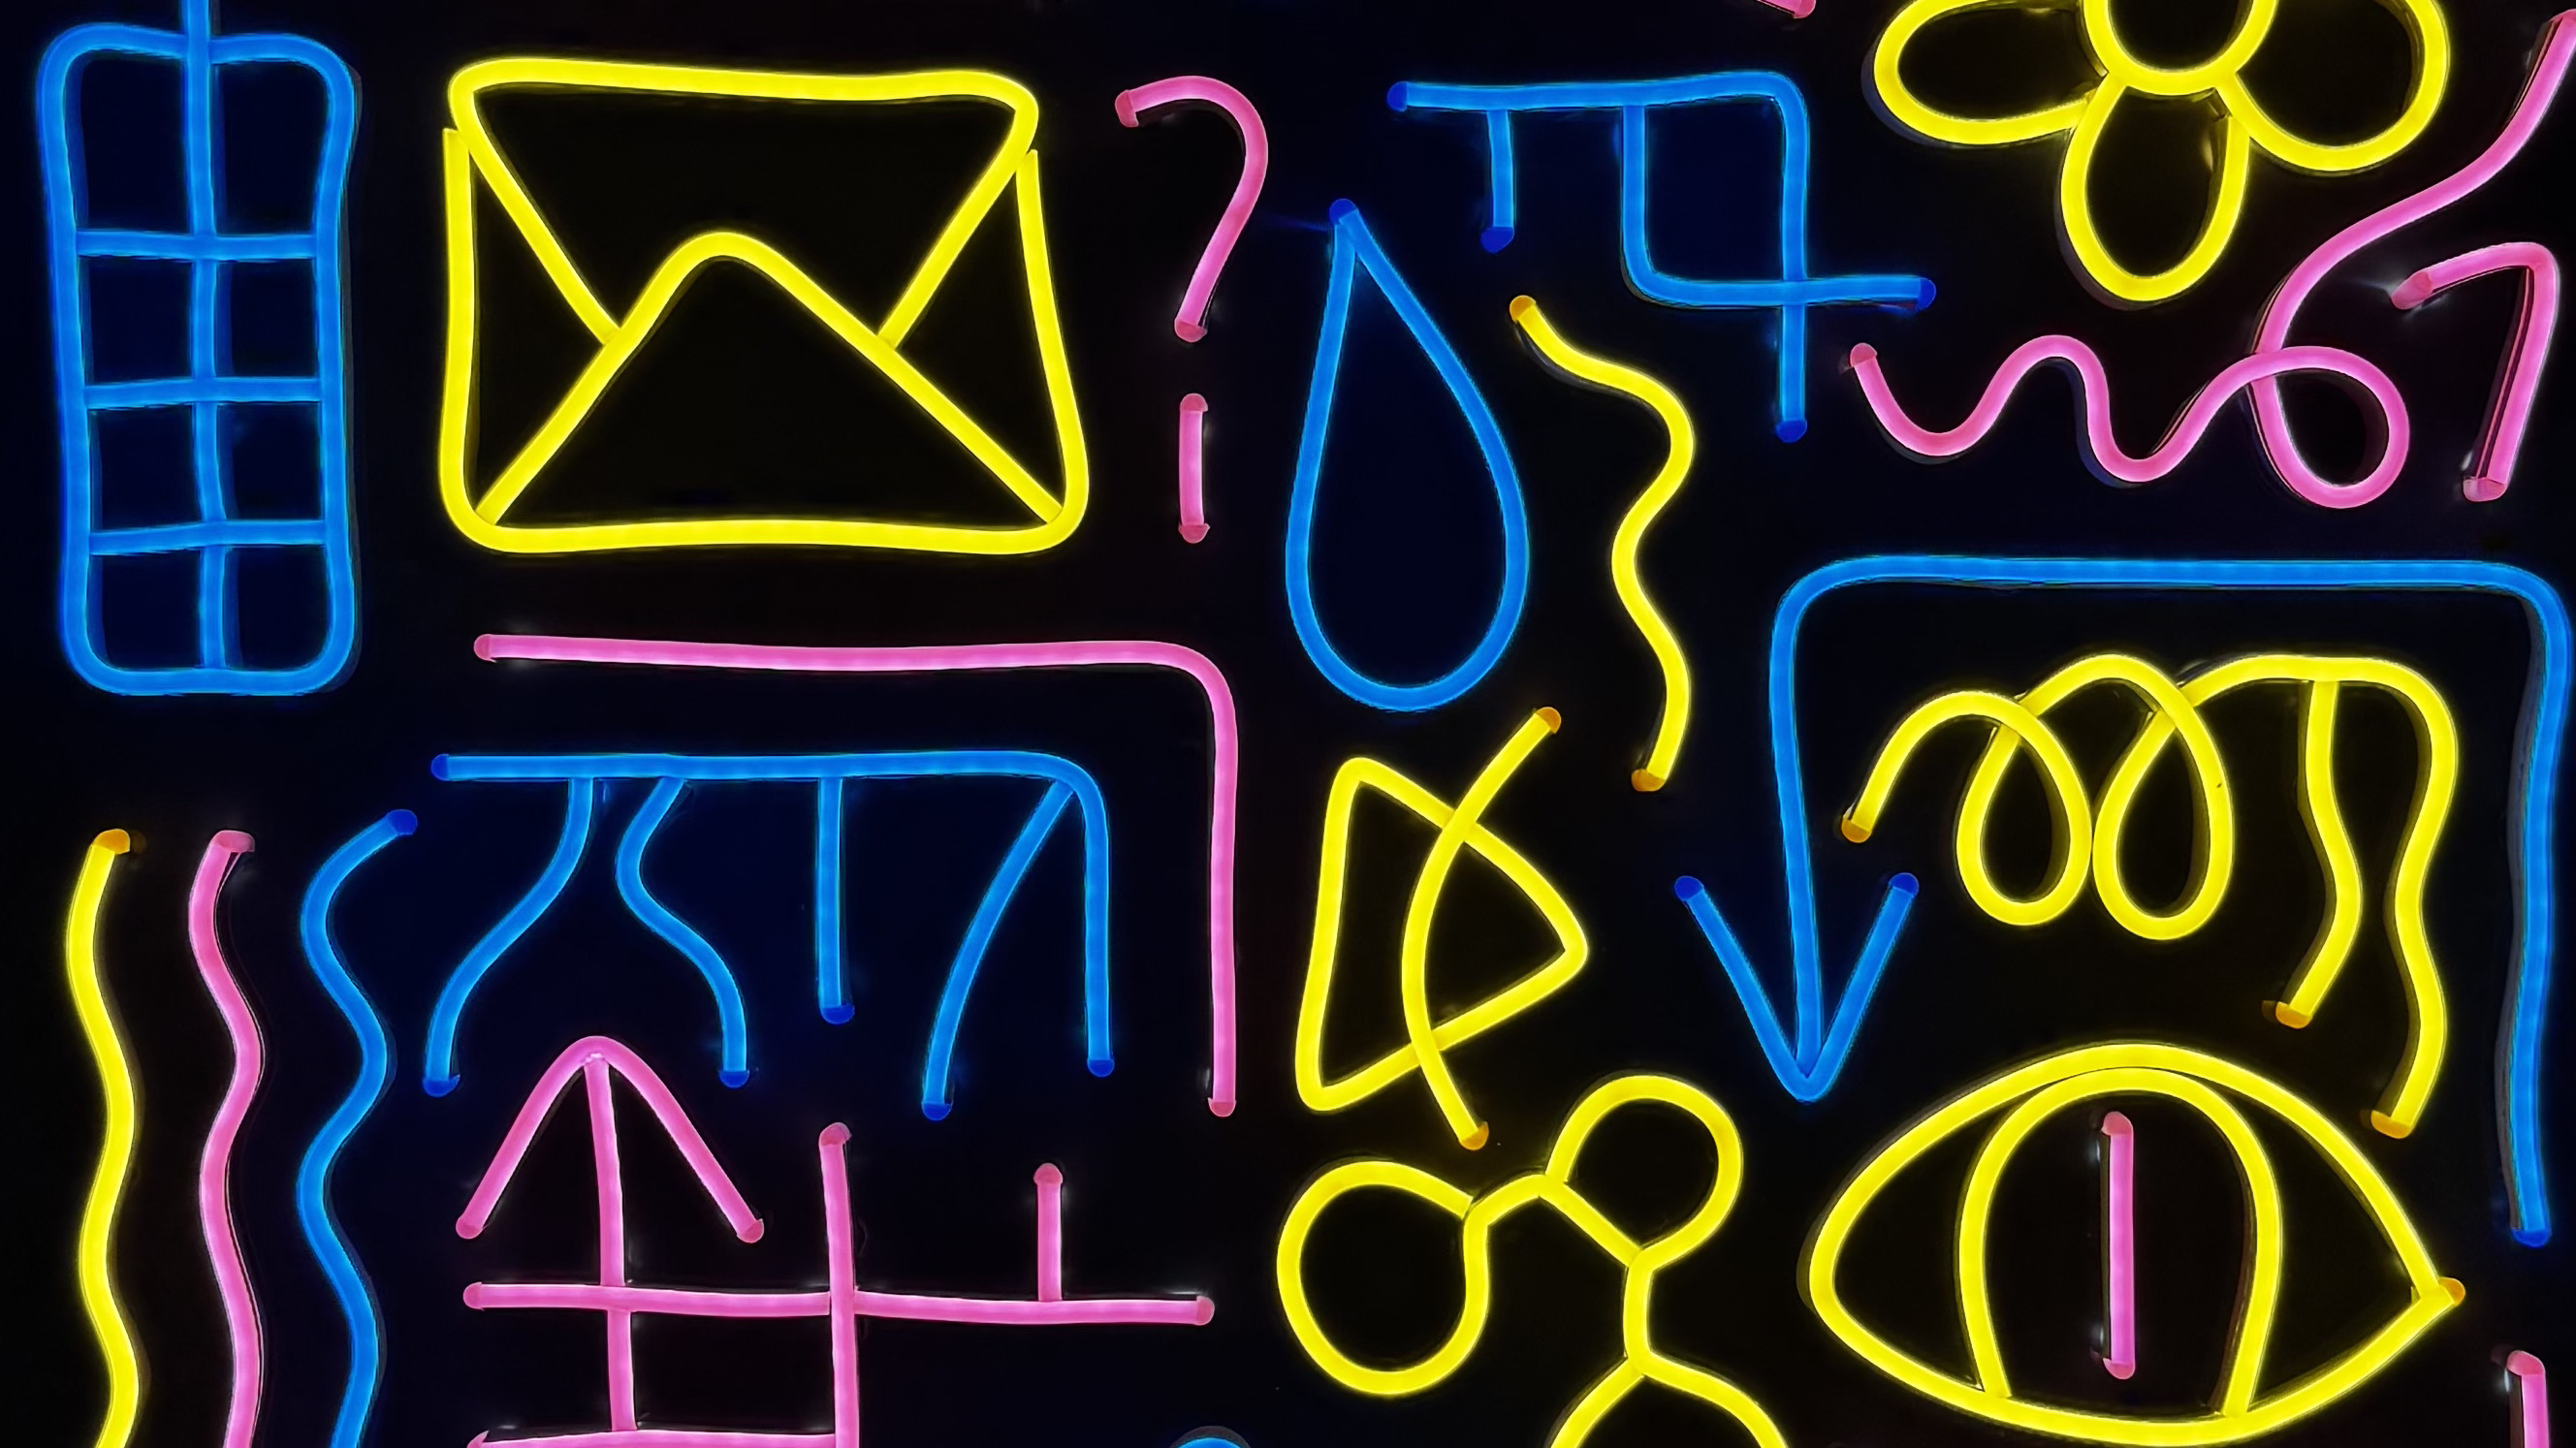
Custom LED Art Installation
Hand-crafted an illuminated wall installation translating the intricate linework of artist Vinnie Hager into physical form. Features dozens of hand-formed flexible LED segments, discrete micro-soldering, high-density concealed wire management, and DFM reflections.
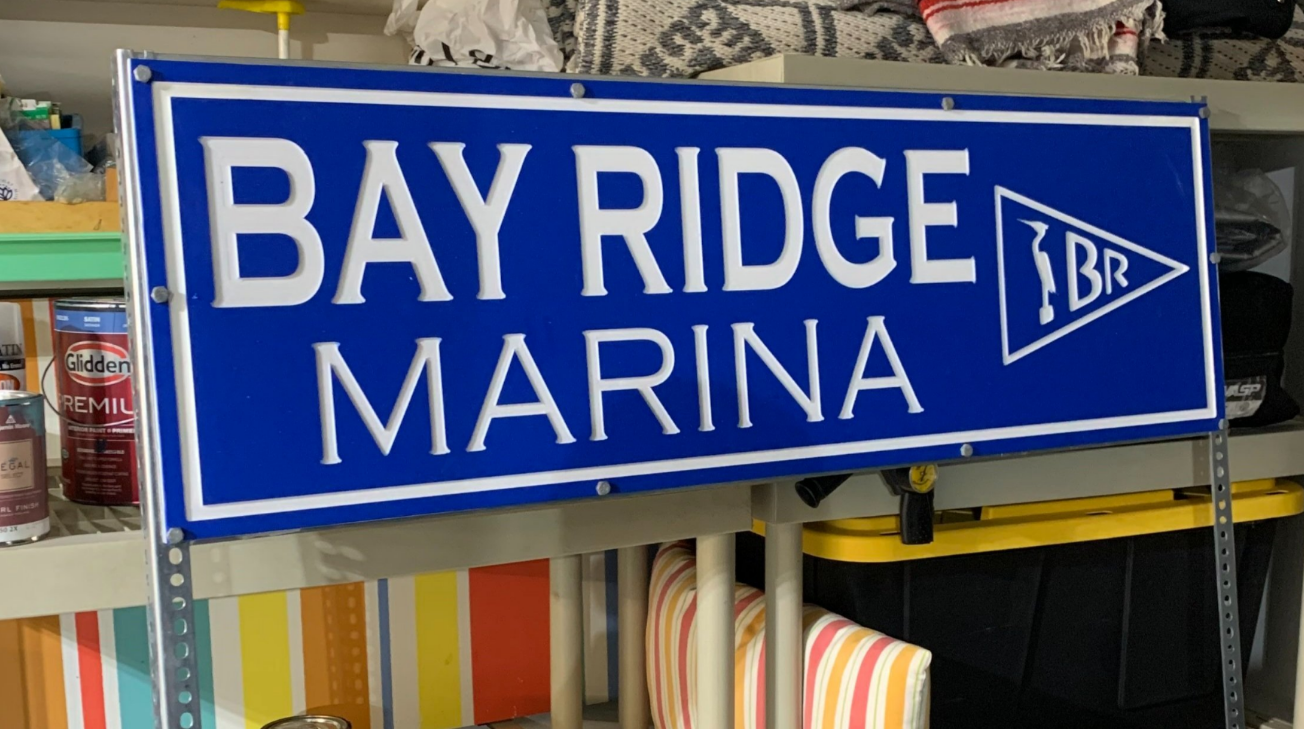
Weekend & Rapid Fabrication Projects
A curated anthology of rapid prototypes, targeted repairs, and community initiatives — spanning CNC-machined marine wayfinding signage, reverse-engineered 3D printed adapters, upcycled laser goods, and fluid flow jug modifications.